Human-Following Robot
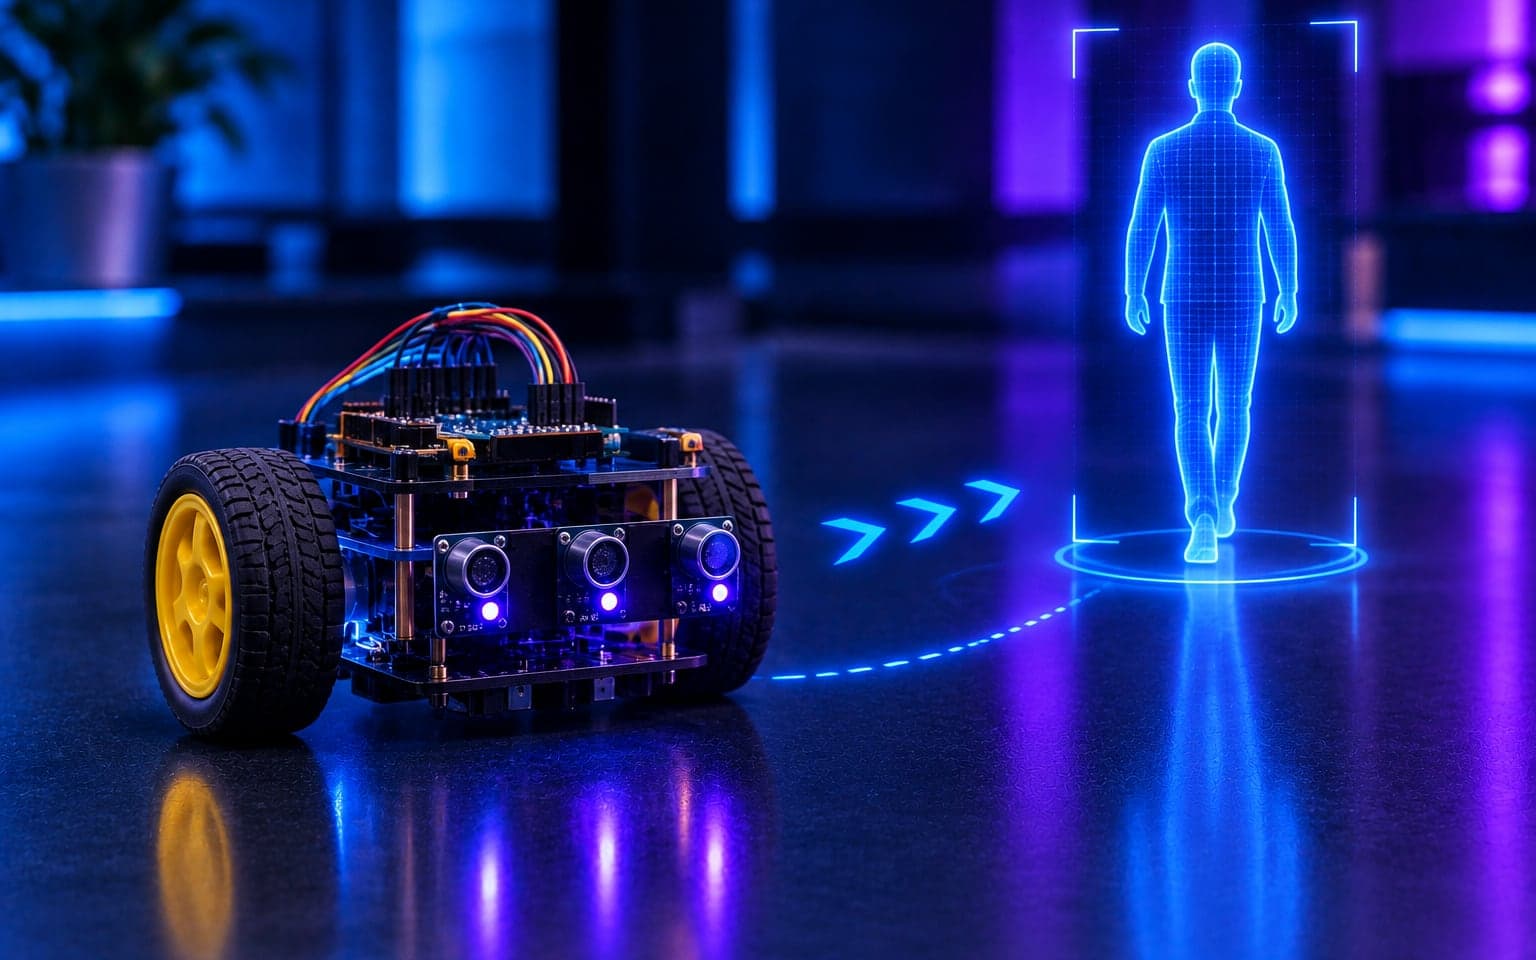
A compact robot that tracks and follows a person with three IR sensors.
Three infrared sensors detect direction and movement so the robot turns left, right or drives straight to stay with its target. Aimed at assistance, retail and warehouse use cases.
README · rendered from GitHub
Human Following Robot


Overview / Introduction
The Human Following Robot is a simple and intelligent robot that uses three infrared sensors to follow a person (or any black path/leg) by detecting direction and movement. This project utilizes an Arduino Uno, IR sensors, and a motor driver to dynamically control the robot's motion — forward, left, or right — based on the relative position of a moving object or a central signal detected by the IR sensors.
Features
- Follows a person or object using three IR sensors
- Smart decision-making: turns left, right, or moves straight
- Controlled by L298N Motor Driver
- Real-time detection using digital IR sensors
- Easy to build and modify
Hardware Components
| Component | Quantity |
|---|---|
| Arduino UNO | 1 |
| IR Sensors | 3 |
| L298N Motor Driver | 1 |
| DC Motors | 4 |
| Robot Chassis | 1 |
| Wheels | 4 |
| Jumper Wires | - |
| Power Supply (Battery Pack) | 1 |
Software Requirements
- Arduino IDE
- Arduino Board Library
- USB Cable for Arduino
- Serial Monitor (for debugging, optional)
Pin Configuration
| Function | Arduino Pin |
|---|---|
| Left IR Sensor | D3 |
| Right IR Sensor | D2 |
| Middle IR Sensor | D4 |
| Left Motor Enable | D10 |
| Left Motor IN1 | D9 |
| Left Motor IN2 | D8 |
| Right Motor Enable | D5 |
| Right Motor IN1 | D7 |
| Right Motor IN2 | D6 |
Decision-Making Logic
- Middle IR sensor LOW → Go Forward
- Left IR sensor LOW, Right HIGH → Turn Left
- Right IR sensor LOW, Left HIGH → Turn Right
- All sensors HIGH → Stop (Lost track)
Function Descriptions
goForward()— Sets both motors to move forward at defined speedturnLeft()— Rotates the robot to the leftturnRight()— Rotates the robot to the rightstopMotors()— Halts all motor movement
How to Run
- Assemble all components as per the wiring table.
- Open Arduino IDE and paste the code.
- Upload the code to your Arduino UNO board.
- Place the robot in front of a human leg or dark object.
- Power the robot and watch it follow the target!
Sensors & Motor Driver Explained
IR Sensors
The robot uses three IR sensors (Left, Middle, Right) to detect reflected IR light. These sensors work based on infrared reflection:
- White/Reflective surface → Reflects IR → Sensor reads LOW
- Black/Absorptive surface (like clothes) → Absorbs IR → Sensor reads HIGH
- The robot compares values from all three sensors to detect which direction to move in to follow a person or leg.
L298N Motor Driver
The L298N Motor Driver Module is used to control the two DC motors of the robot. It acts as an interface between the low-power Arduino and the high-power motors.
Features:
- Can control the direction and speed of two DC motors.
- Accepts PWM (Pulse Width Modulation) signals from Arduino to adjust motor speed.
- Has two enable pins (ENA, ENB) and four control pins (IN1, IN2, IN3, IN4) connected to the Arduino.
Working:
- ENA / ENB: Used to control the speed of motors via
analogWrite(). - IN1/IN2 (for Motor A) and IN3/IN4 (for Motor B): Used to control motor direction via
digitalWrite().
Example:
digitalWrite(IN1, HIGH);
digitalWrite(IN2, LOW);  // Motor moves forward
How to Charge Lithium-Ion
What You Need:
- TP4056 charging module (with or without protection circuit)
- Lithium-Ion battery (typically 3.7V, like an 18650 cell)
- Power source (5V via USB cable or 5V adapter)
Wiring Connections
| TP4056 Pin | Connects To | Description |
|---|---|---|
| BAT+ | Battery Positive (+) | Connect to battery's positive terminal |
| BAT- | Battery Negative (–) | Connect to battery's negative terminal |
| IN+ | 5V Power Positive | USB VCC or 5V adapter |
| IN- | 5V Power Ground | USB GND or adapter GND |
| OUT+ | Output Positive (Optional) | Same as BAT+ if present |
| OUT- | Output Negative (Optional) | Same as BAT– if present |
Charging Status (LED Indicators)
- 🔴 Red LED ON → Charging
- 🟢 Blue/Green LED ON → Fully Charged (approx. 4.2V)
TP4056 Specifications
- Input Voltage: 4.5V – 5.5V (recommended: 5V)
- Charging Cut-off Voltage: 4.2V
- Max Charging Current: 1A (default, adjustable by changing onboard resistor)
Charging Steps
- Connect BAT+ and BAT- to the Lithium-ion battery terminals.
- Connect IN+ and IN- to a 5V power supply (USB or adapter).
- Observe LED indicators:
- Red = Charging
- Green/Blue = Fully Charged
- Disconnect power once fully charged (unless using protected module).
Safety Tips
- Never leave charging unattended.
- Use only genuine 3.7V Li-ion batteries.
- Avoid short circuits on BAT terminals.
- Do not reverse polarity — it can damage the module and the battery.
- Use TP4056 with protection for safer charging and discharging.
Demonstration
The robot will continuously monitor IR input and follow a dark object/person as long as it's in front of the middle sensor.
Applications
- Human-following carts or luggage
- Shopping assistants in stores
- Personal delivery bots
- Educational robotic kits
Future Improvements
➕ Implement PID control for smoother and more accurate tracking
➕ Upgrade to vision-based tracking using OpenCV or AI camera
Troubleshooting / Common Issues
- Robot not moving → Check motor power supply and enable pins.
- Sensors not responding → Ensure proper alignment and correct logic levels.
- Wrong turns → Swap motor direction pins or verify sensor logic.
- Low speed or stalling → Check battery voltage and motor connections.
Demo Video
https://github.com/user-attachments/assets/1a332b06-d684-478d-a12b-91c1f452c24d
Credits / Acknowledgements
Developed by Awais Asghar and Muhammad Abdullah
License
This project is licensed under the MIT License. You are free to use, modify, and distribute it with attribution.
More in Robotics
Related projects
 Robotics2024
Obstacle-Avoiding Robot
An ultrasonic rover that stops, reverses and turns around anything in its way.
- Arduino UNO
- C/C++
- HC-SR04
- L298N
- Arduino UNO
- C/C++
- IR sensors